Early bird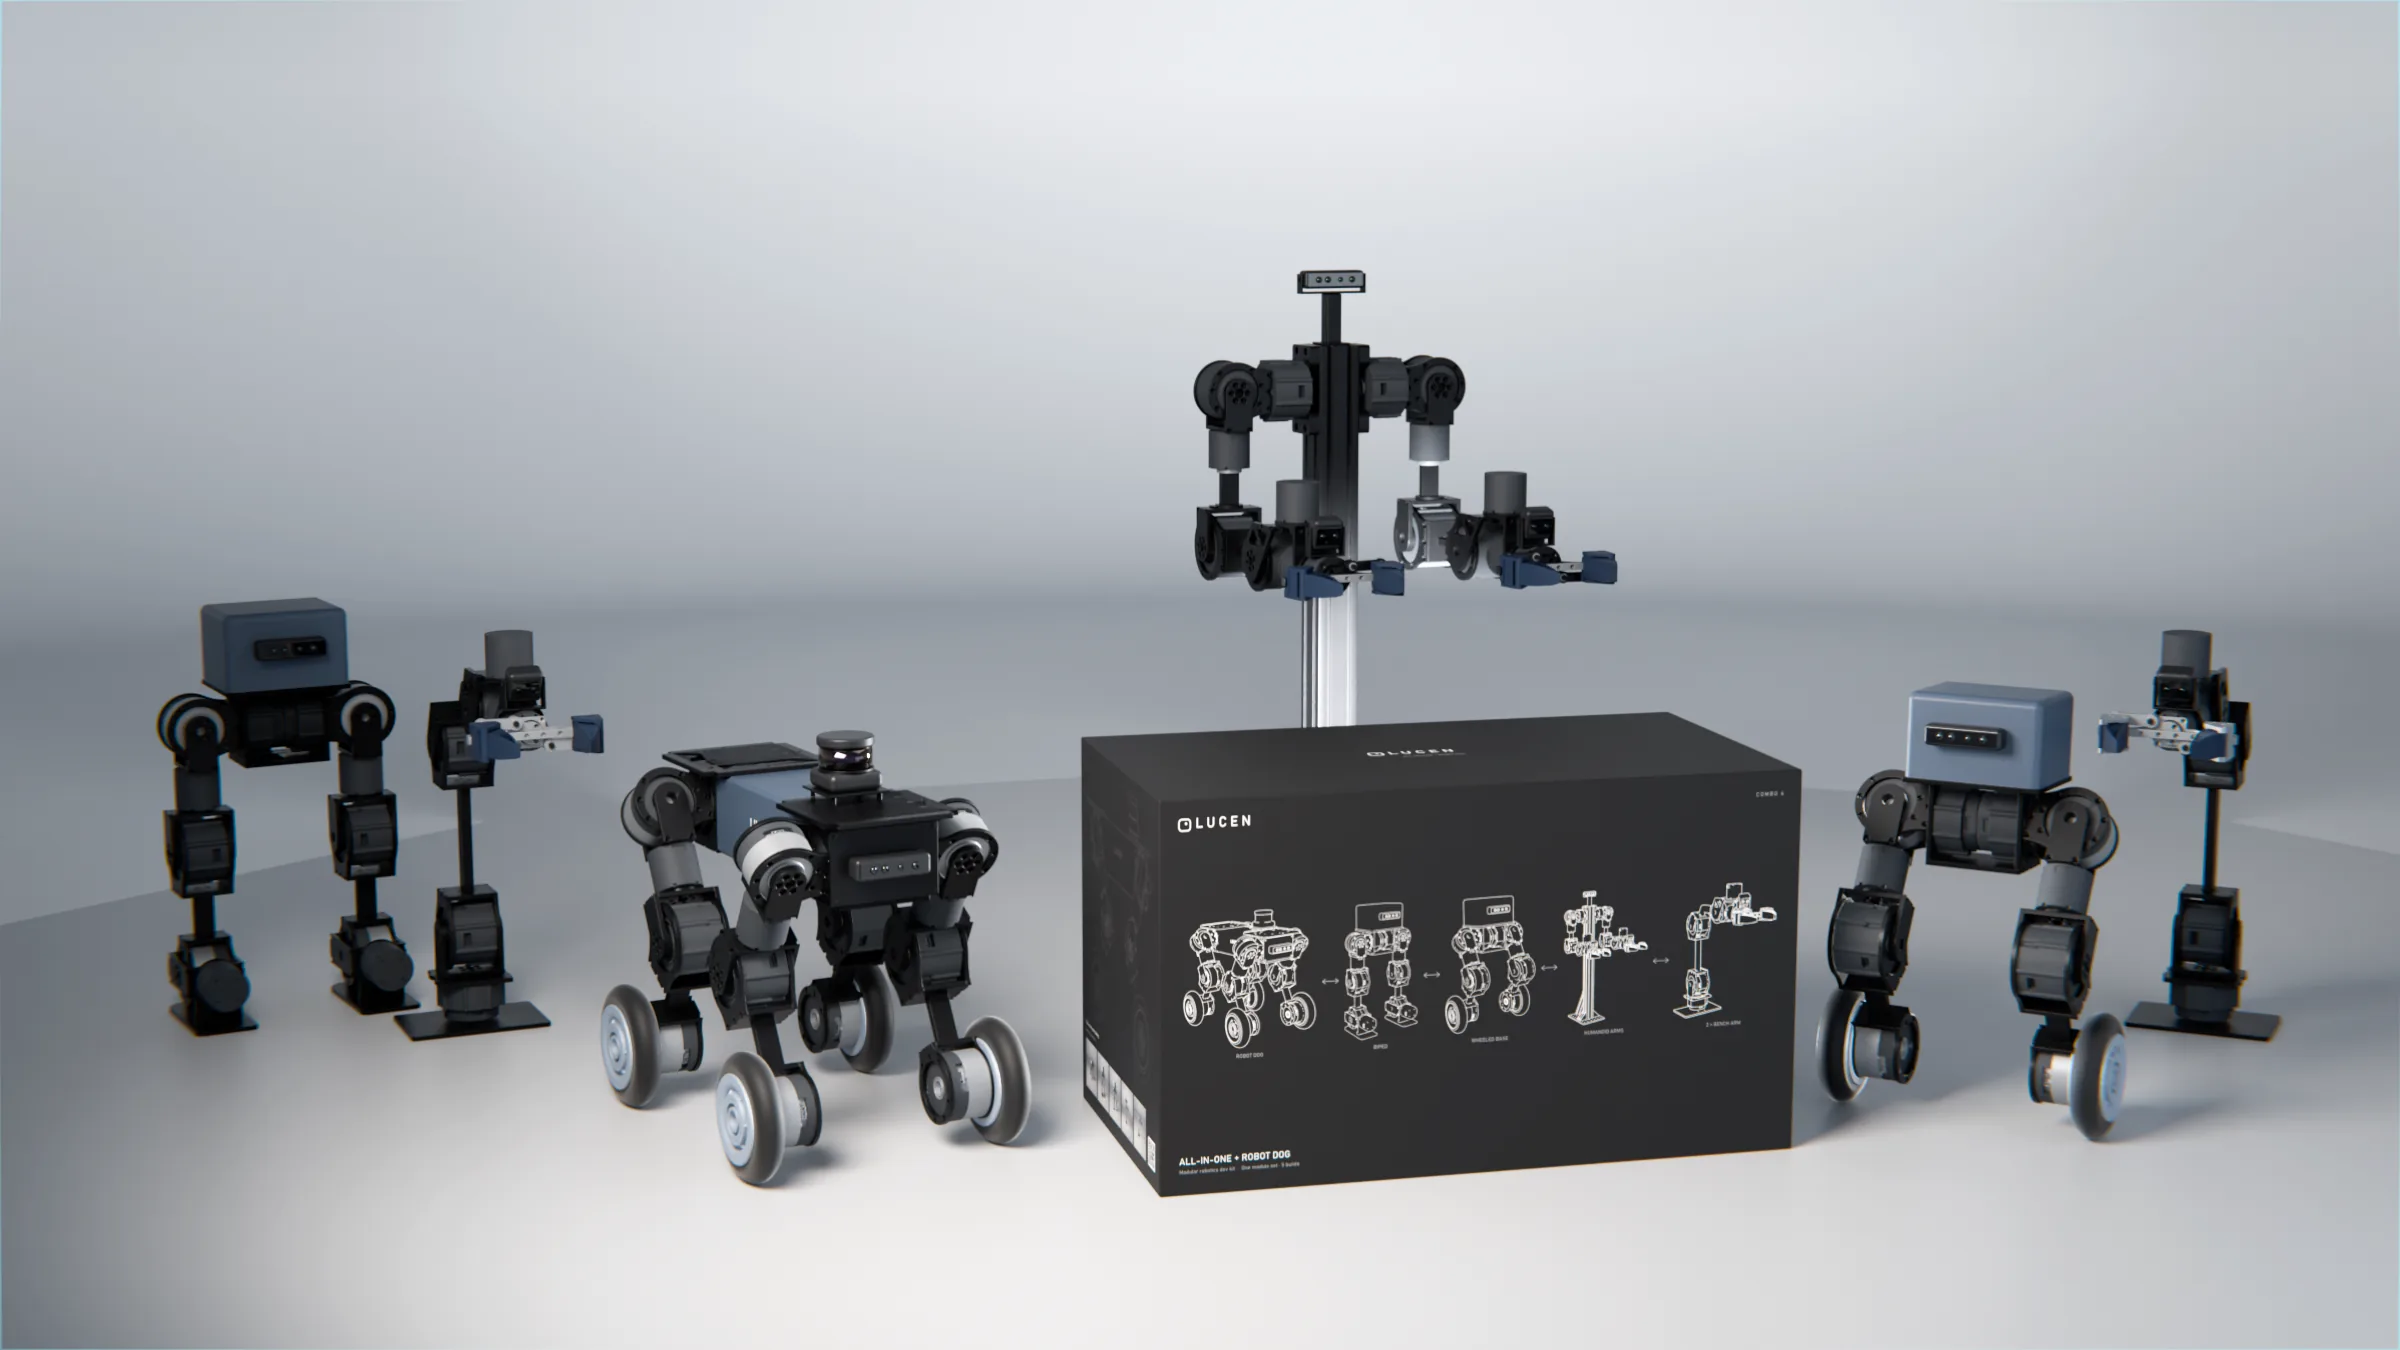
Ultimate
5-in-1 · every build + QuadrupedEverything in the All-in-One, plus the Quadruped. Five robots from one actuator set.
$10,199$10,999Compute included
Pre-order
Biped, wheeled, quadruped and arm robots built from the same actuators. Open firmware, onboard NVIDIA compute, made for labs and classrooms.
Pre-orders open soon · fully refundable any time before your robot ships
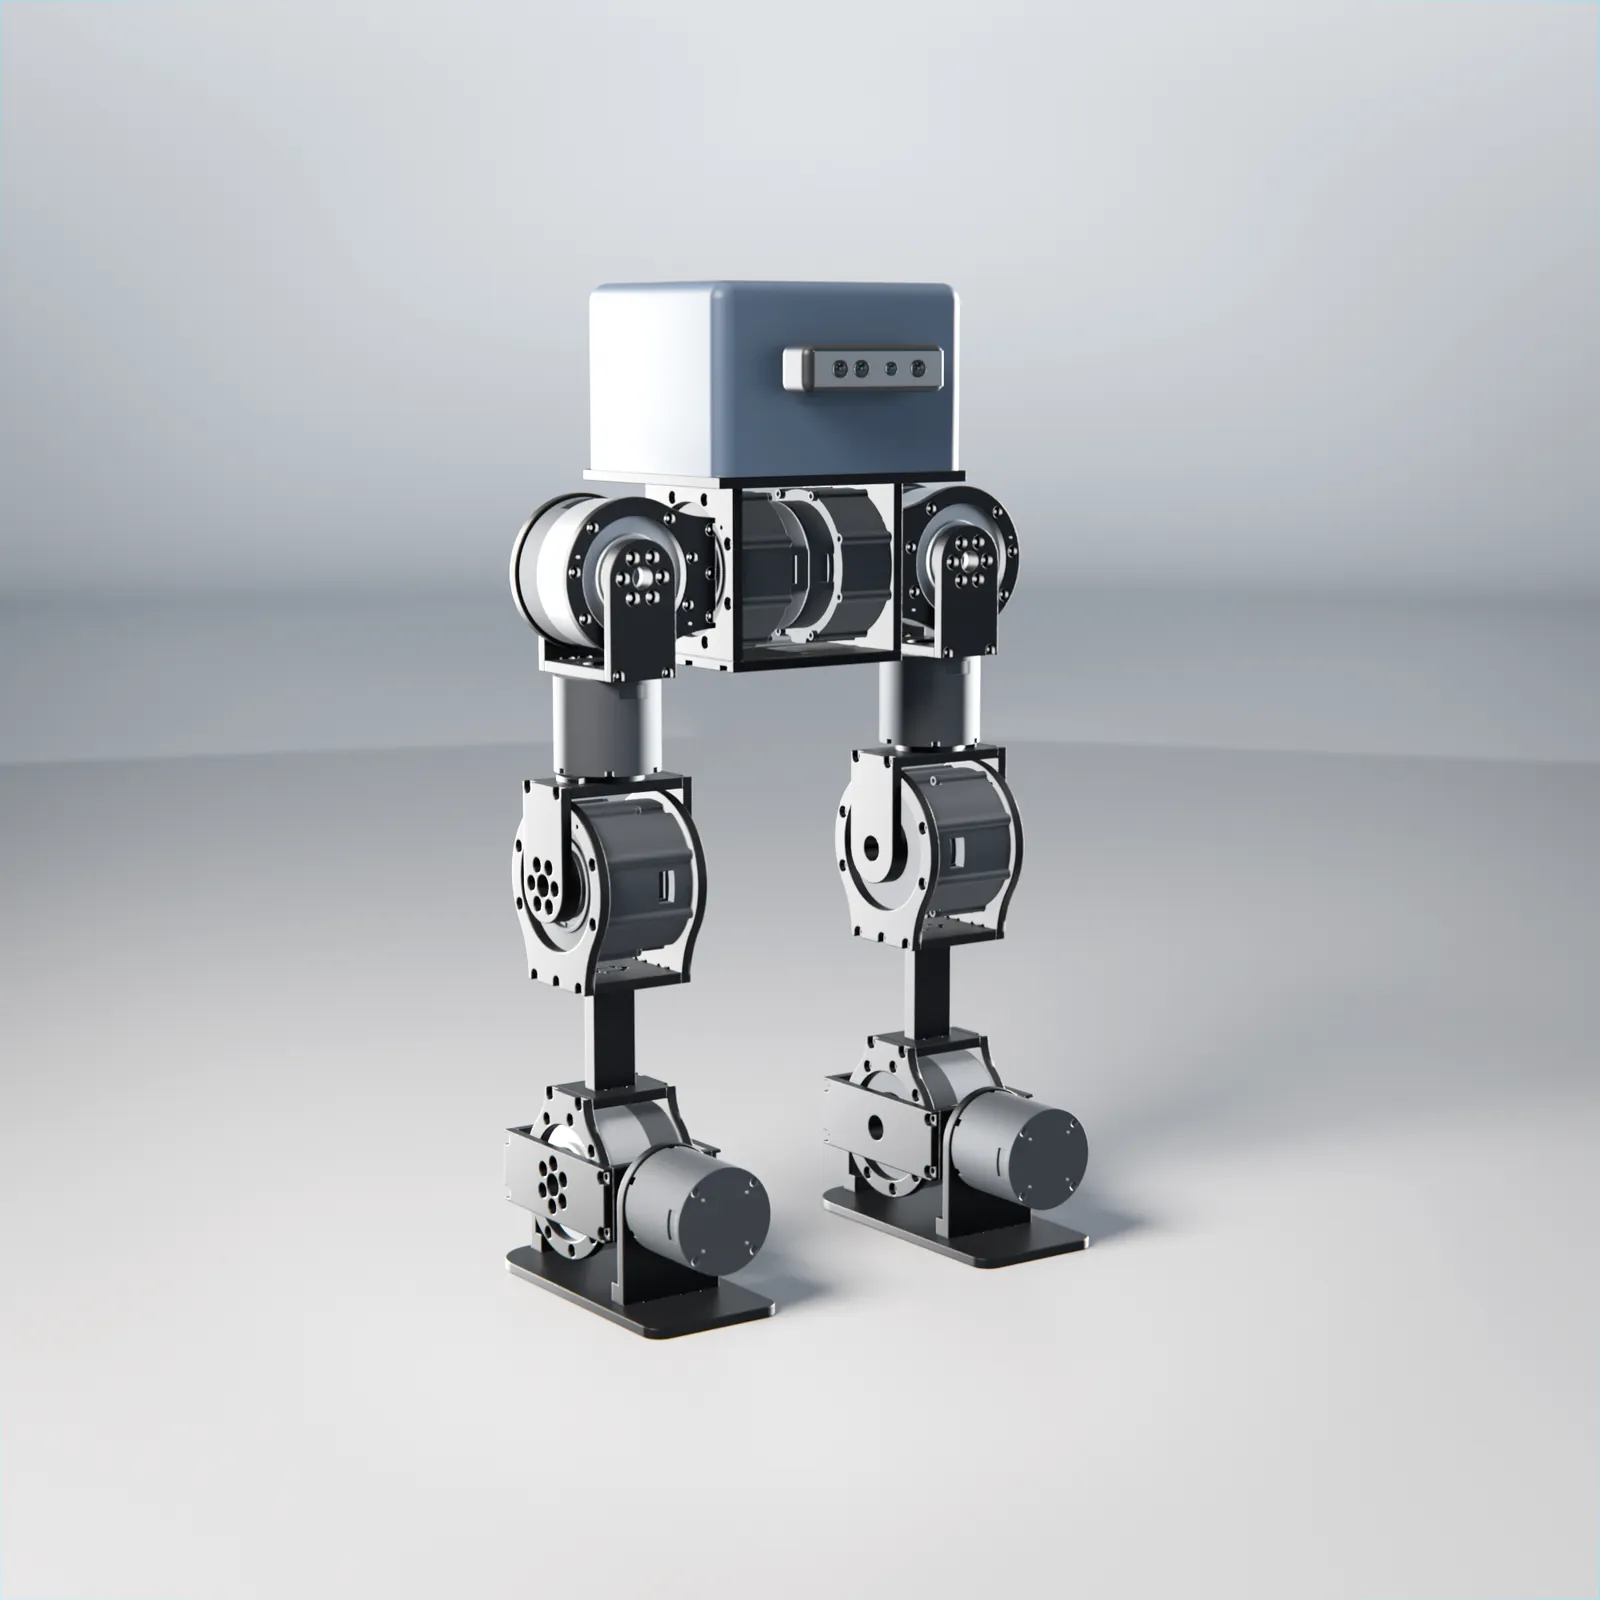
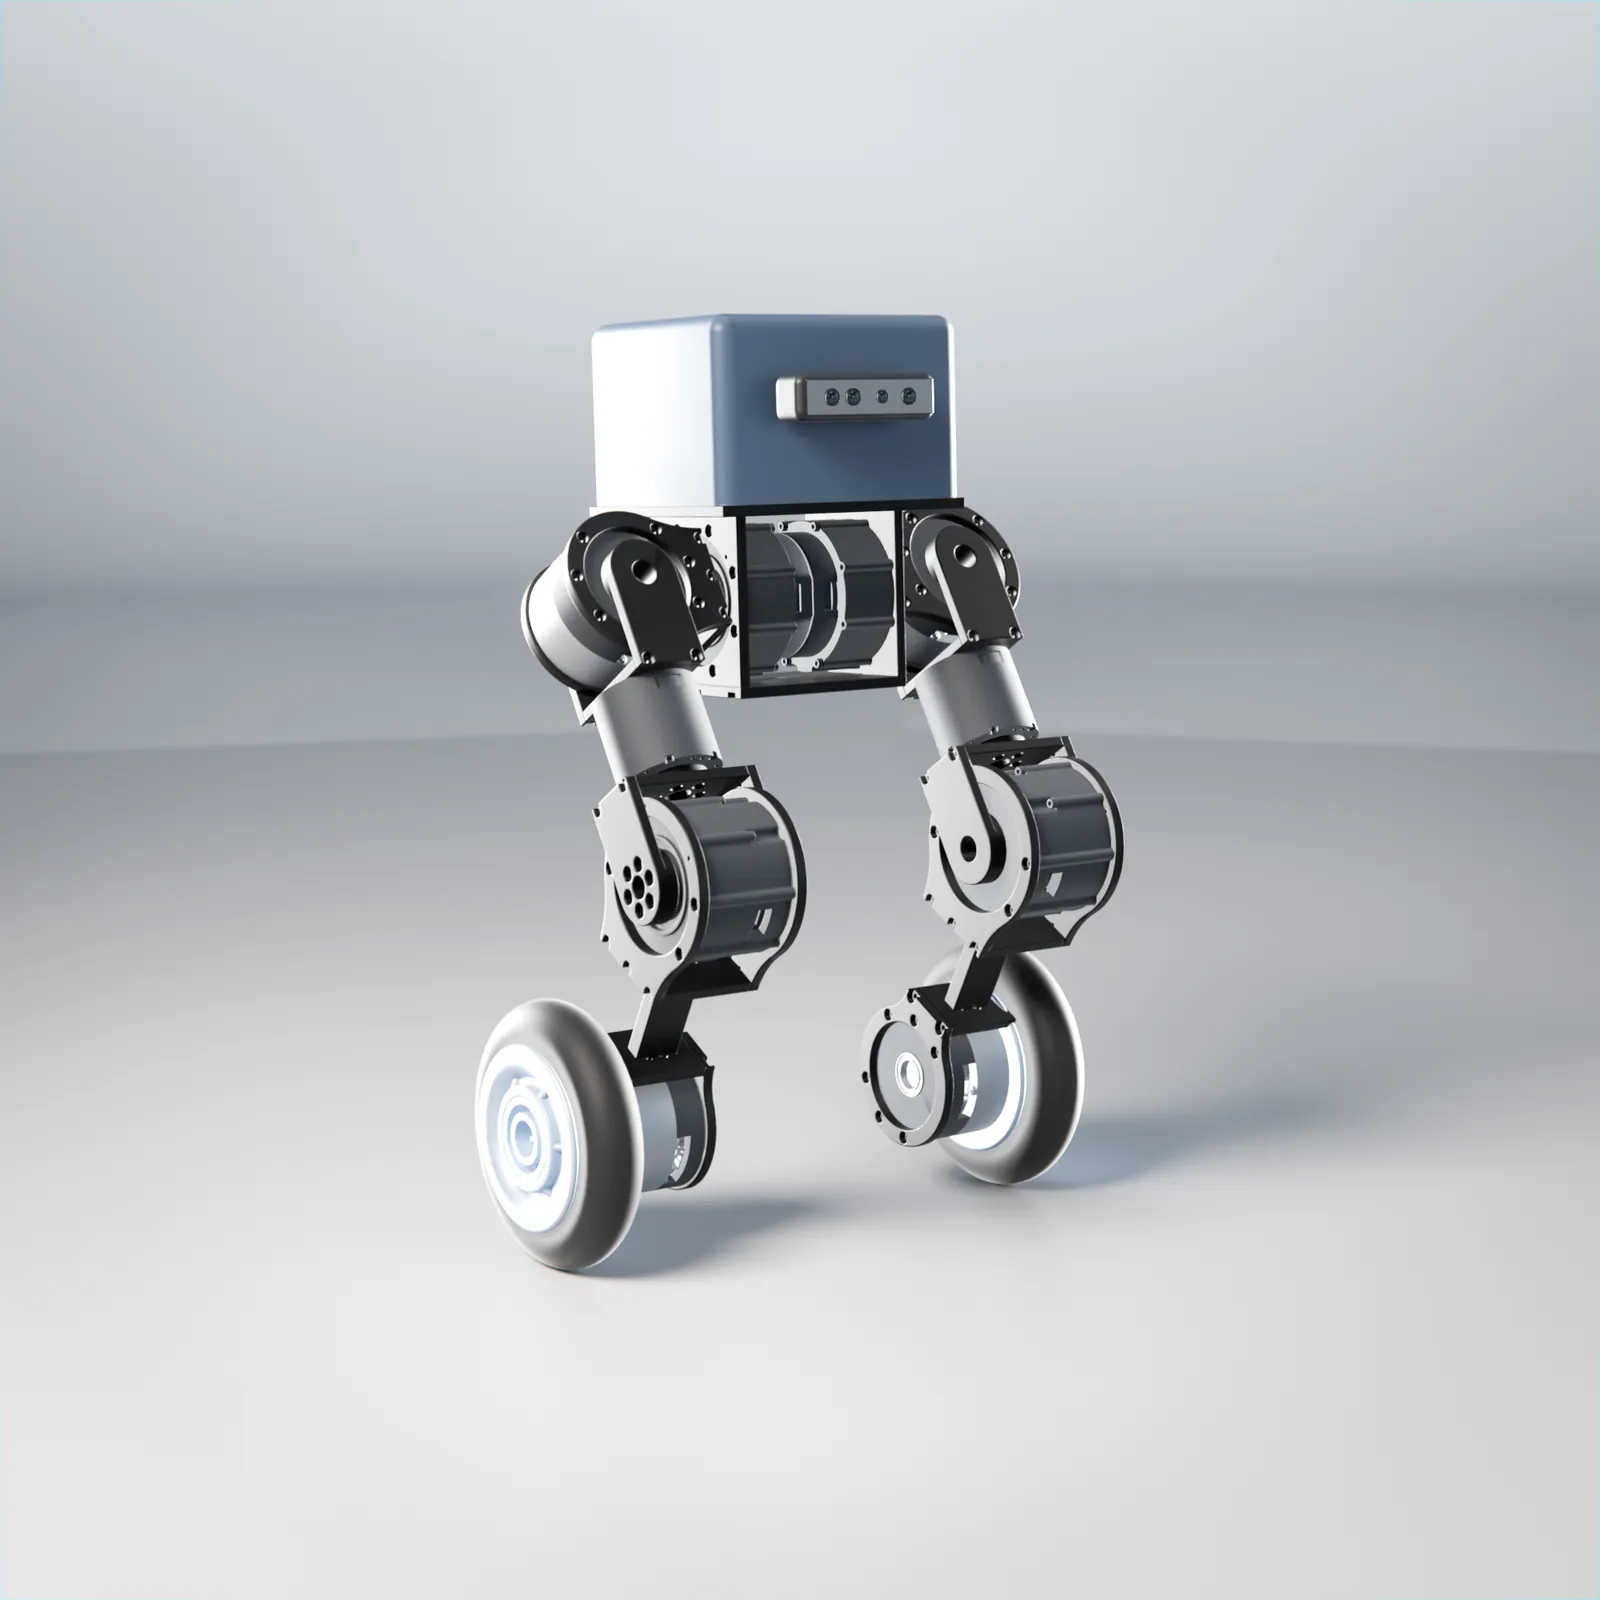
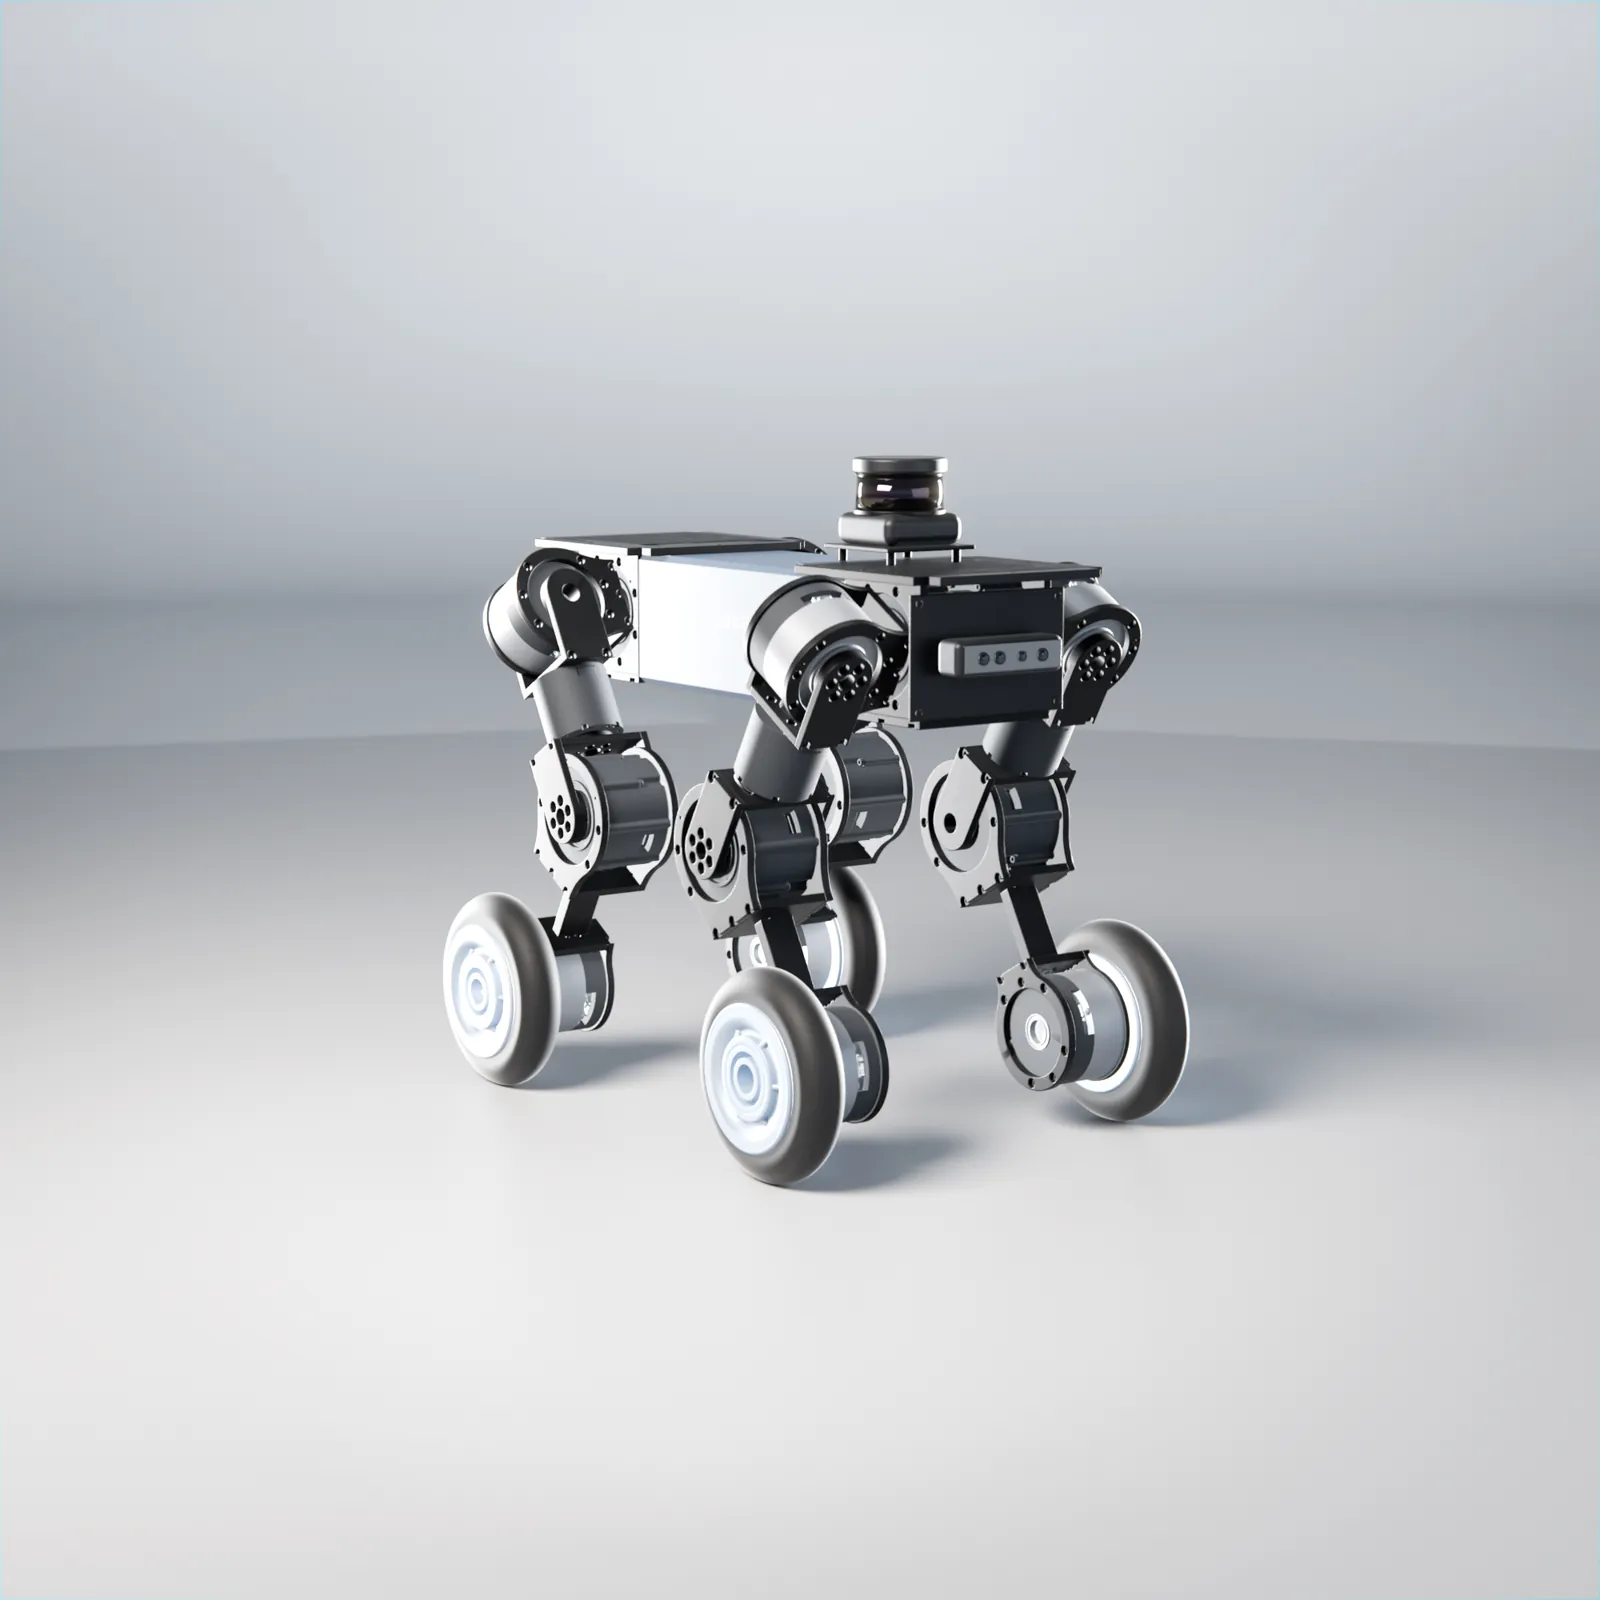
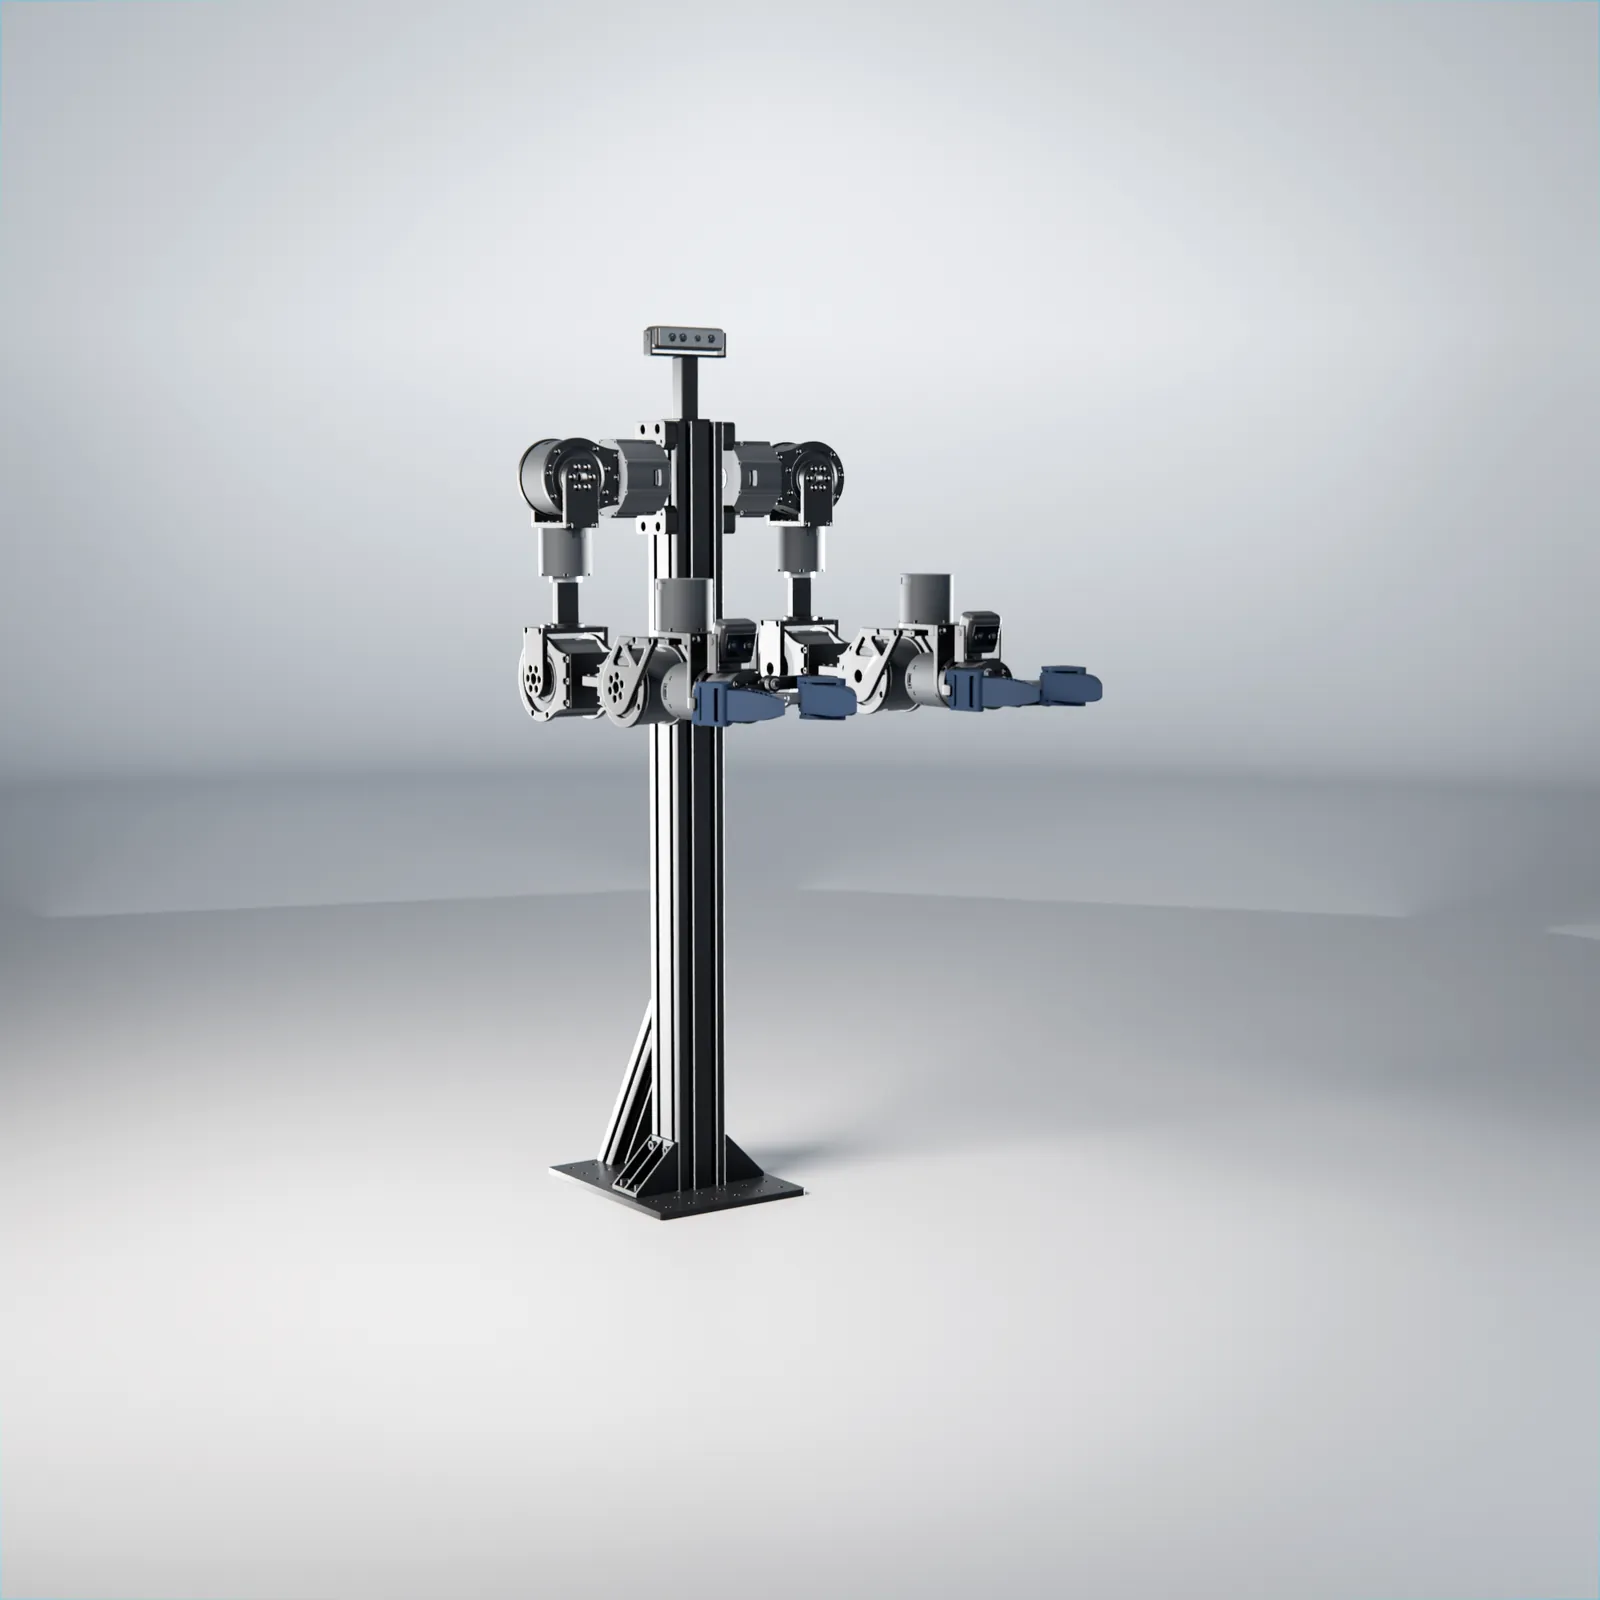
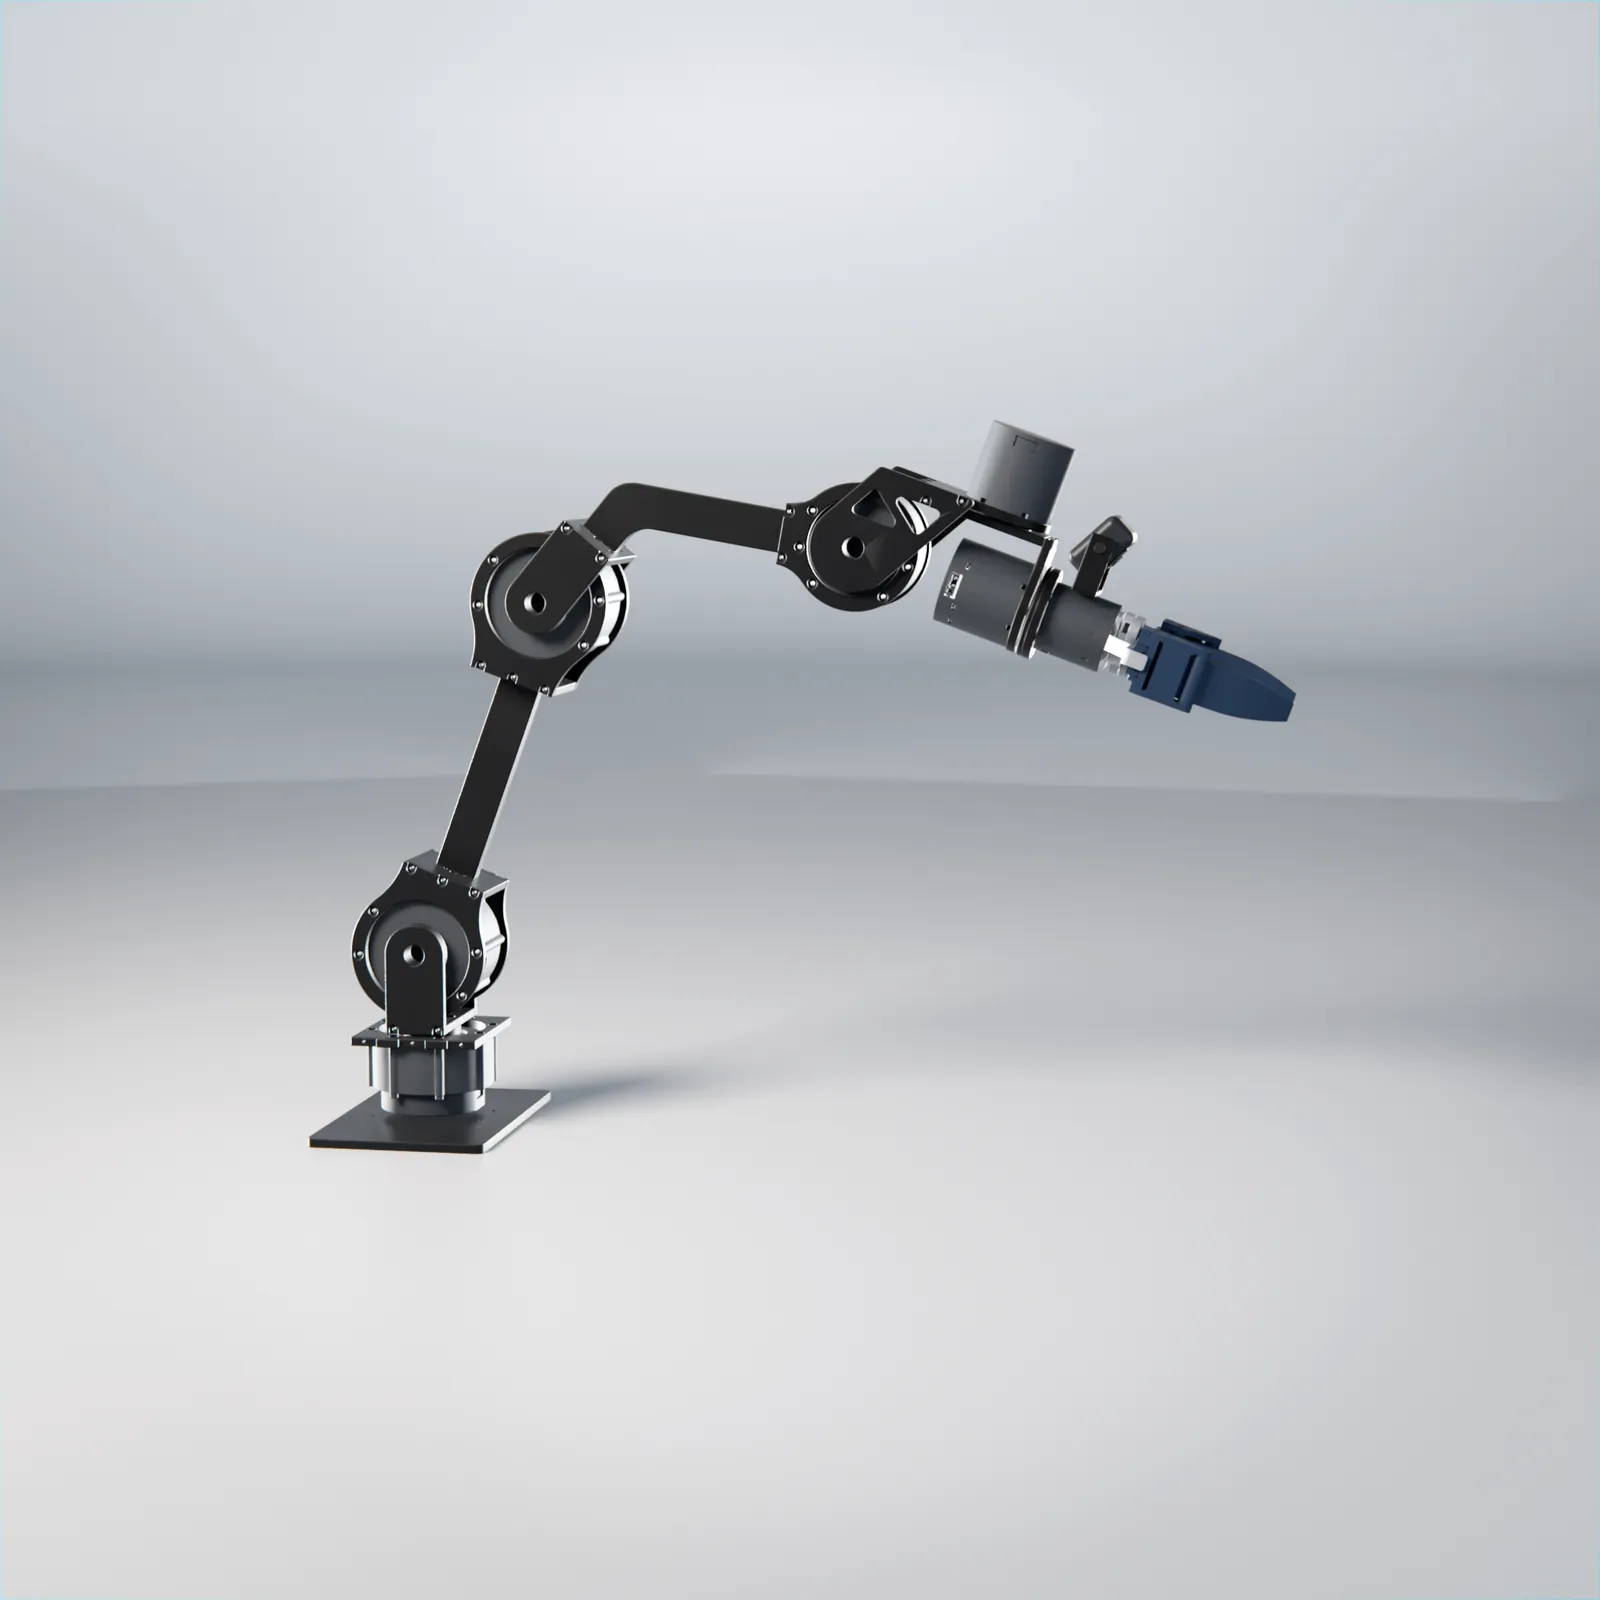 Same actuators · 5 builds
EDU Edition
Unbolt the legs with a hex key. Every actuator is field-replaceable, with no soldering.
Replug the CAN bus, add two actuators, and fit the gripper. Nothing to re-wire.
Same actuators, same controller, same host software. Flash the arm firmware branch and start training.
Every bundle is one actuator set plus conversion kits. Build one robot, then rebuild it as the next with a hex key.
Everything in the All-in-One, plus the Quadruped. Five robots from one actuator set.
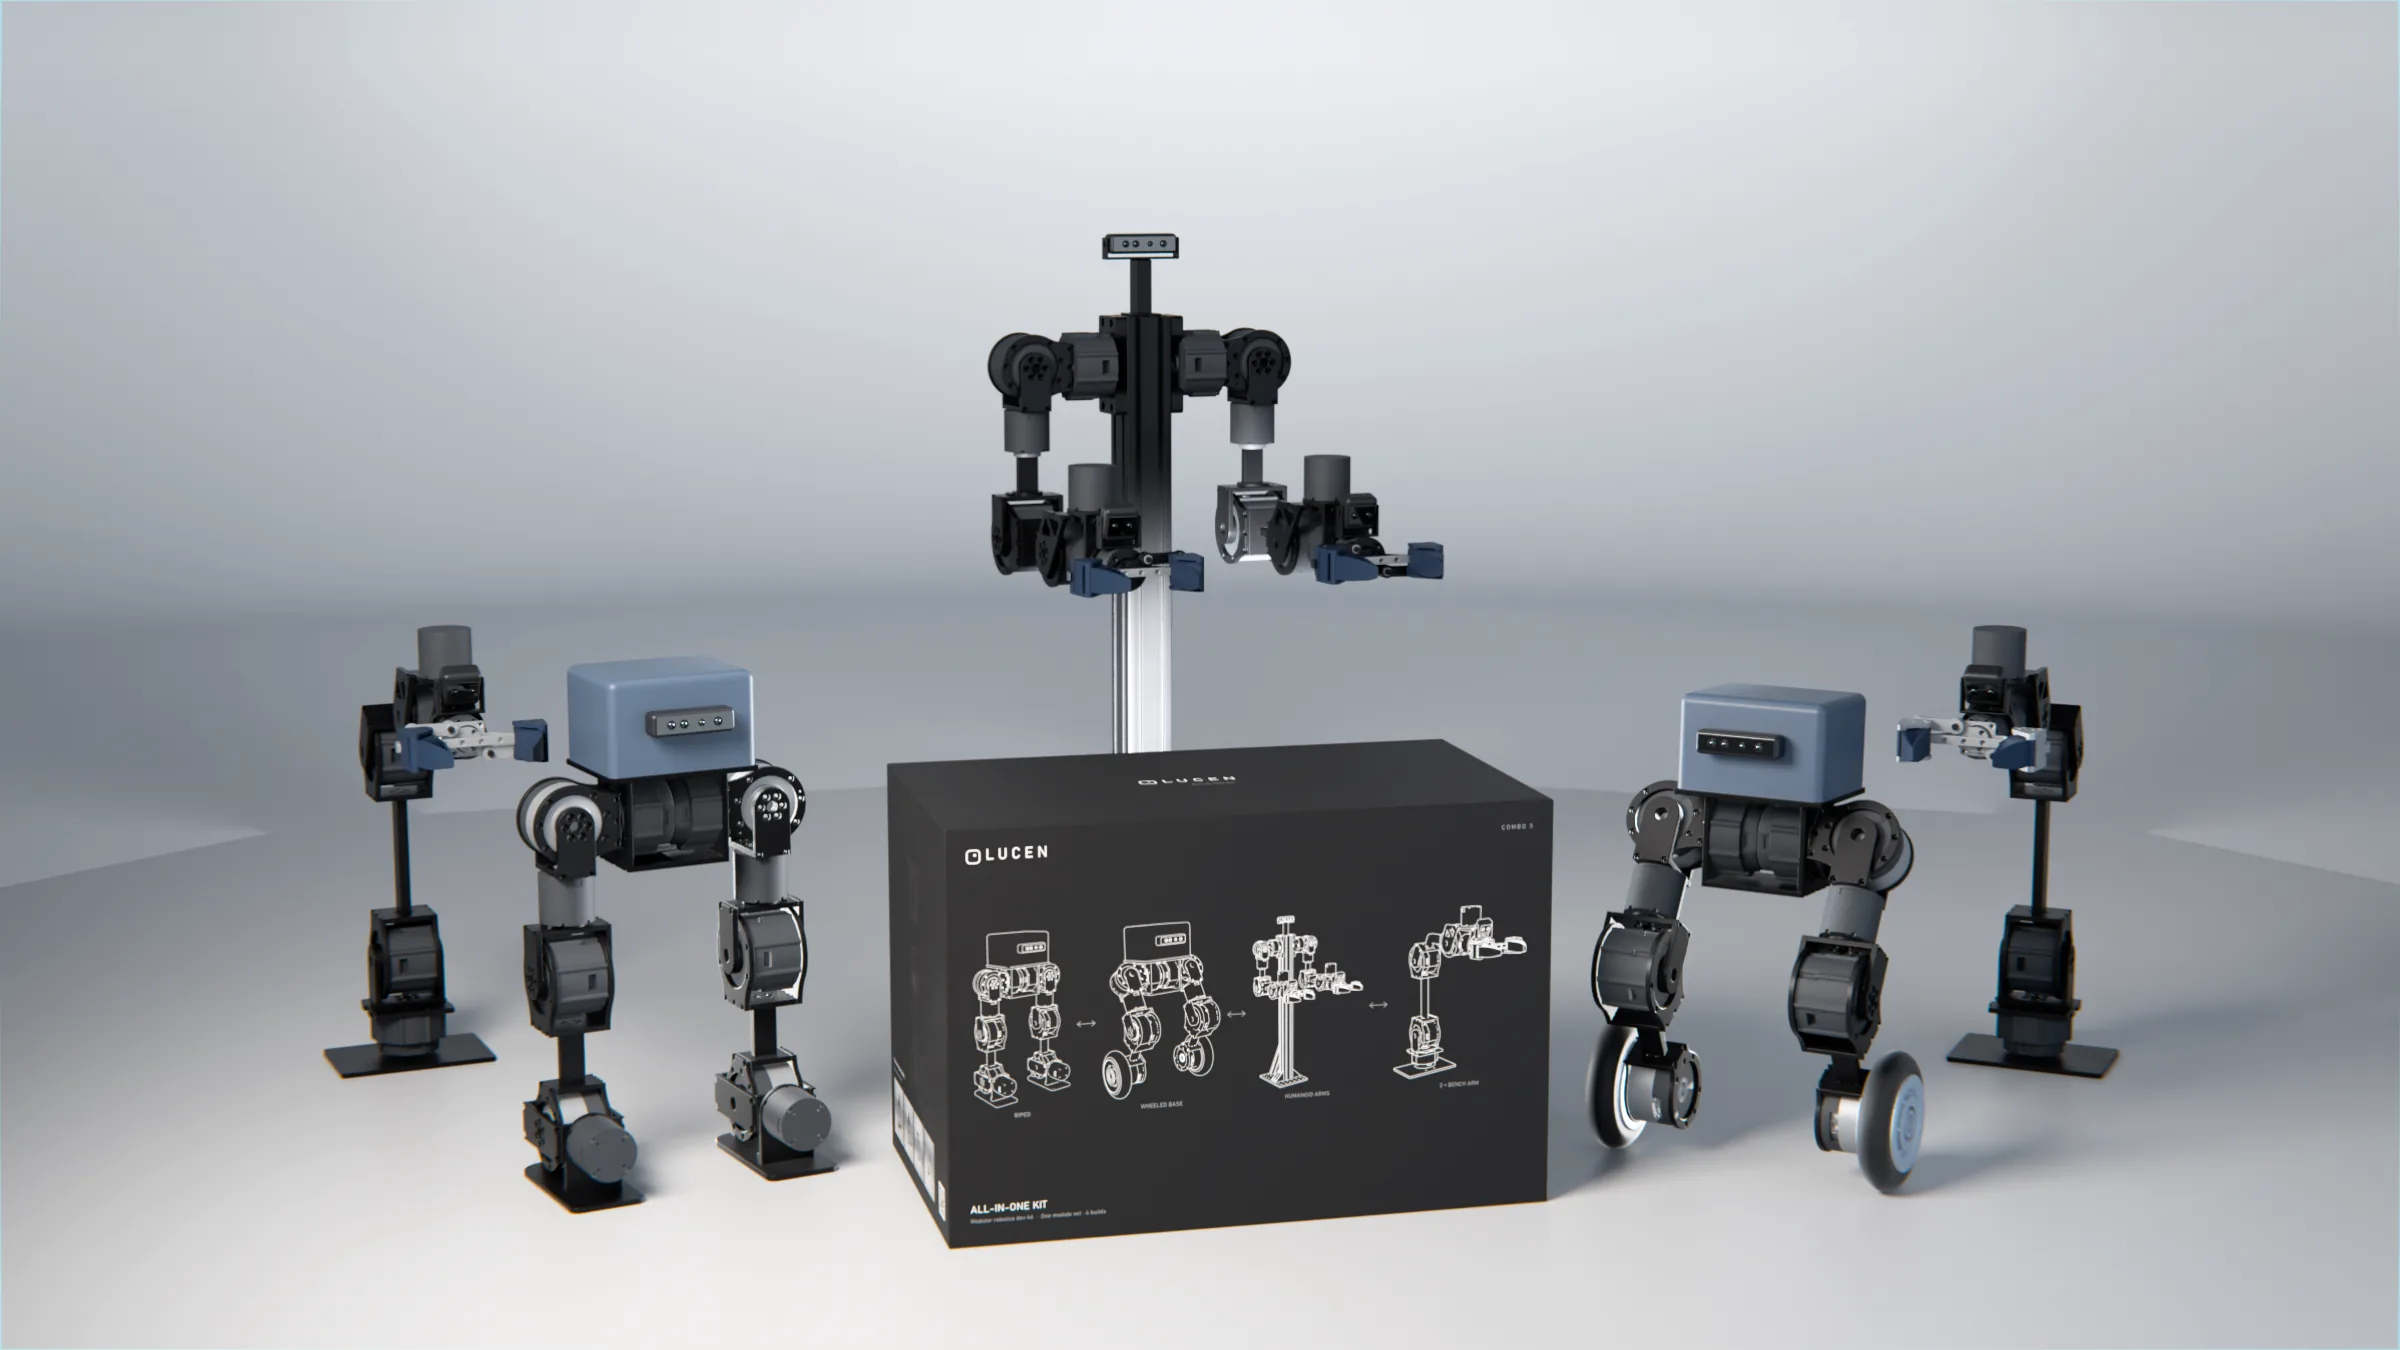
One actuator set and every conversion kit. Walk, roll, and manipulate with two separate arms or both on the stand.
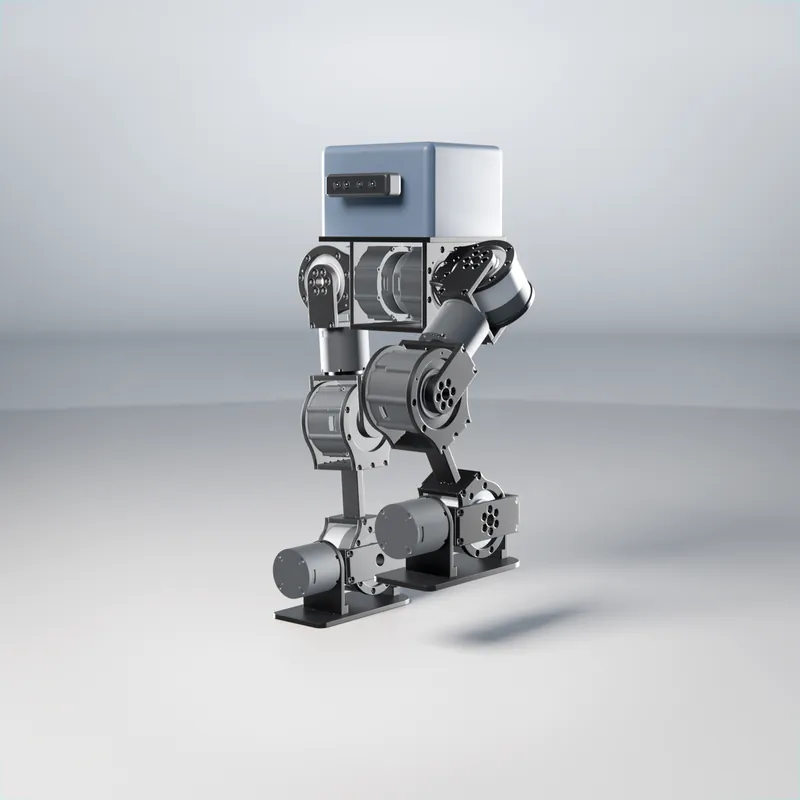 ⇄
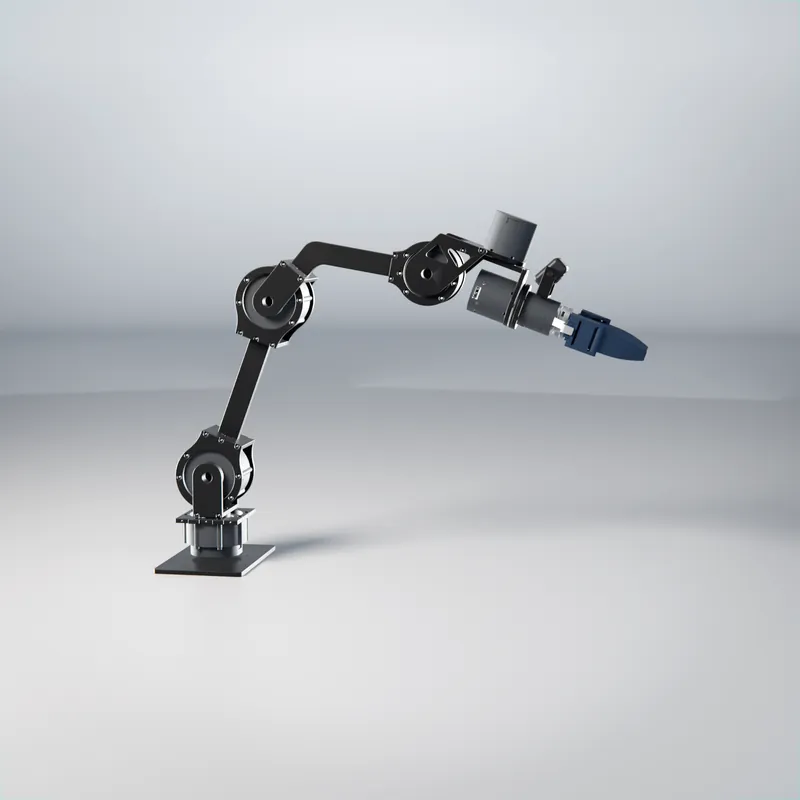
Train locomotion on the Biped, then rebuild it as two separate arms.
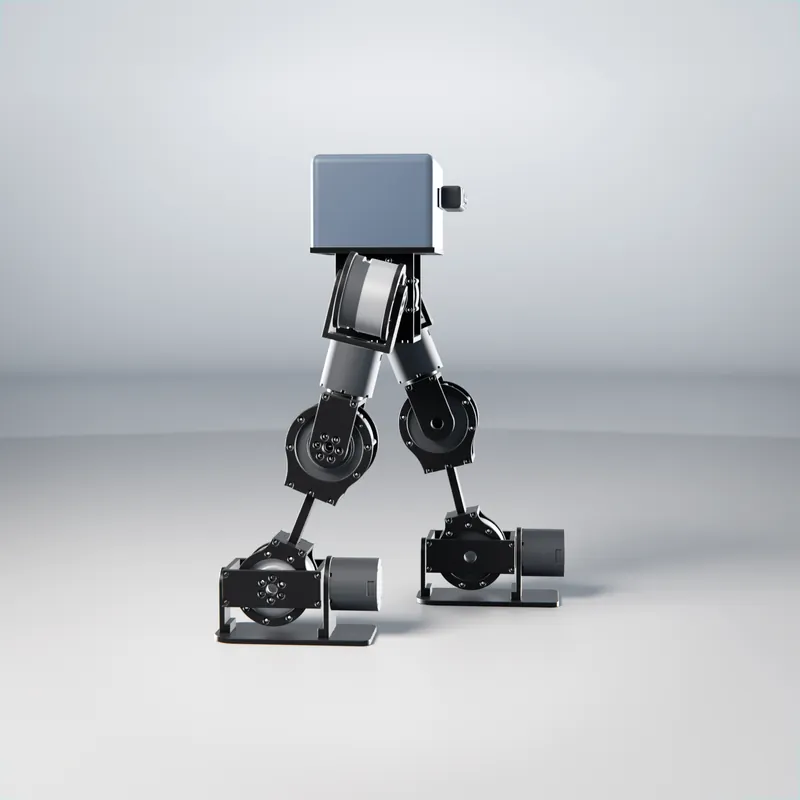 ⇄
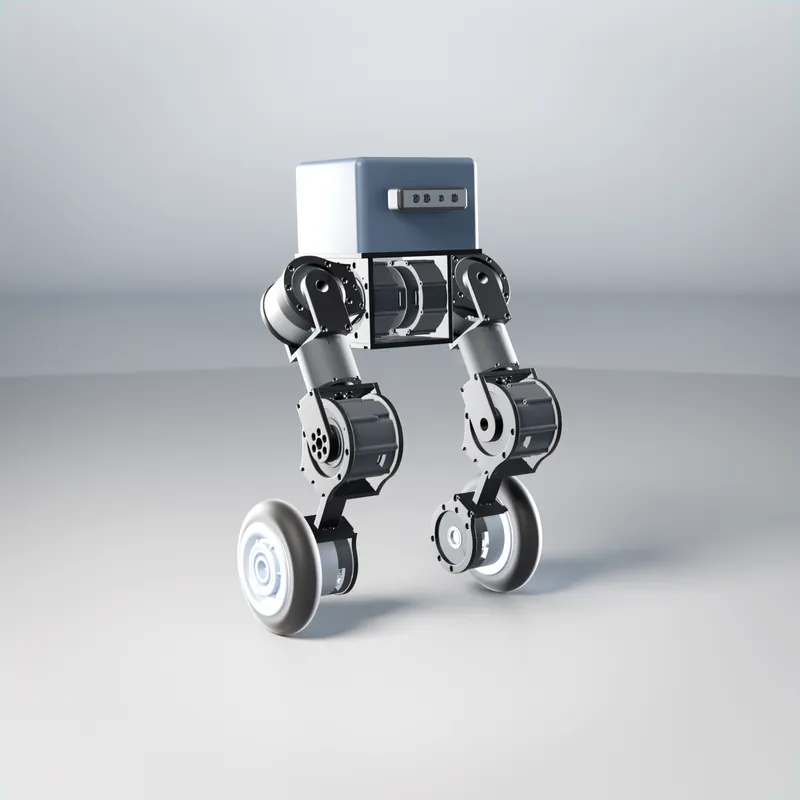
Walk or roll. The Biped plus the wheel conversion, on one actuator set.
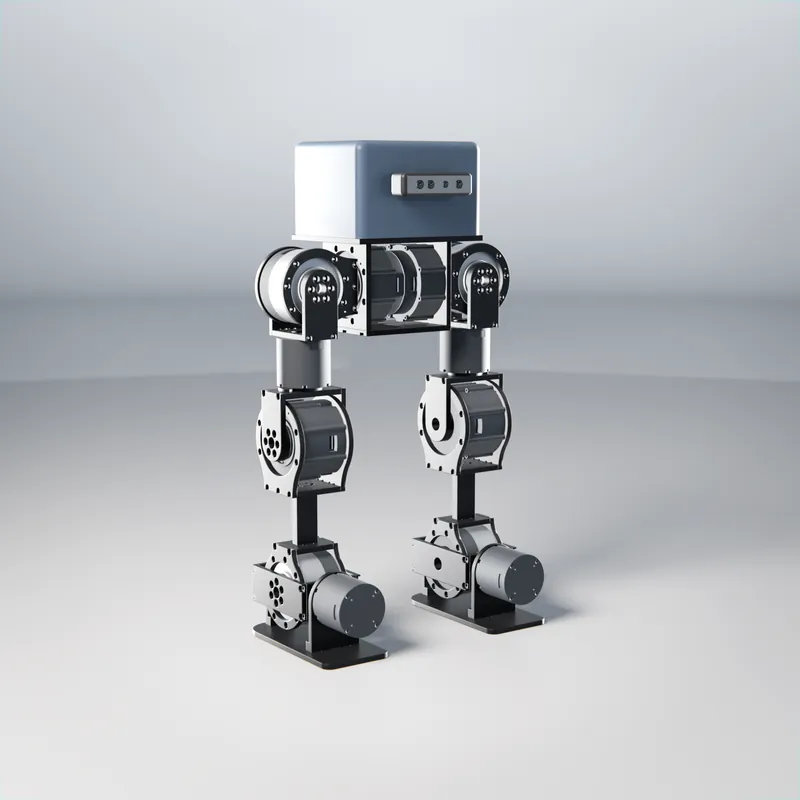 ⇄
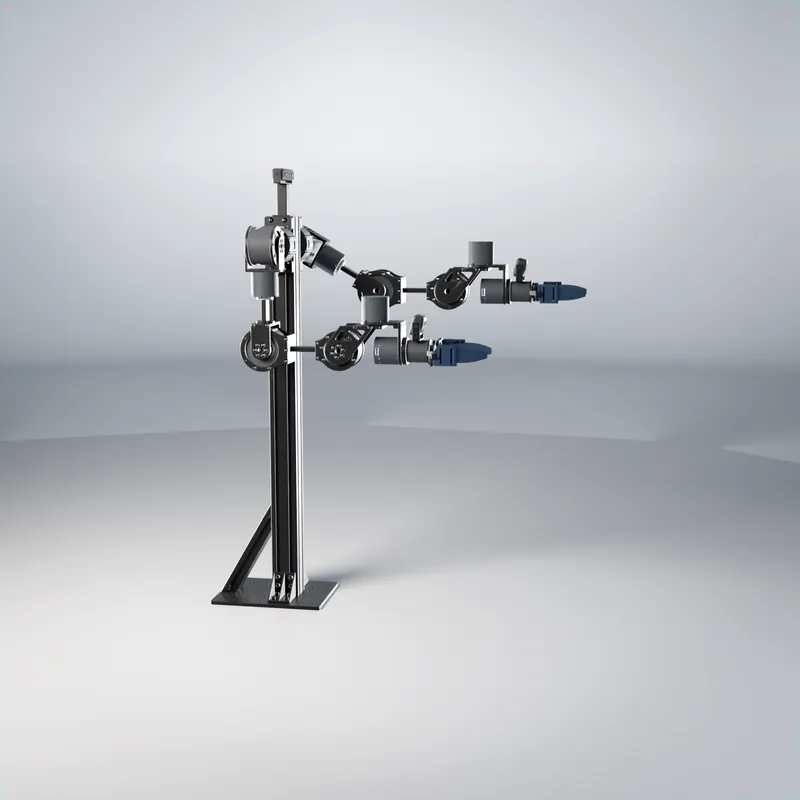
Train locomotion on the Biped, then rebuild it as two arms on a stand.
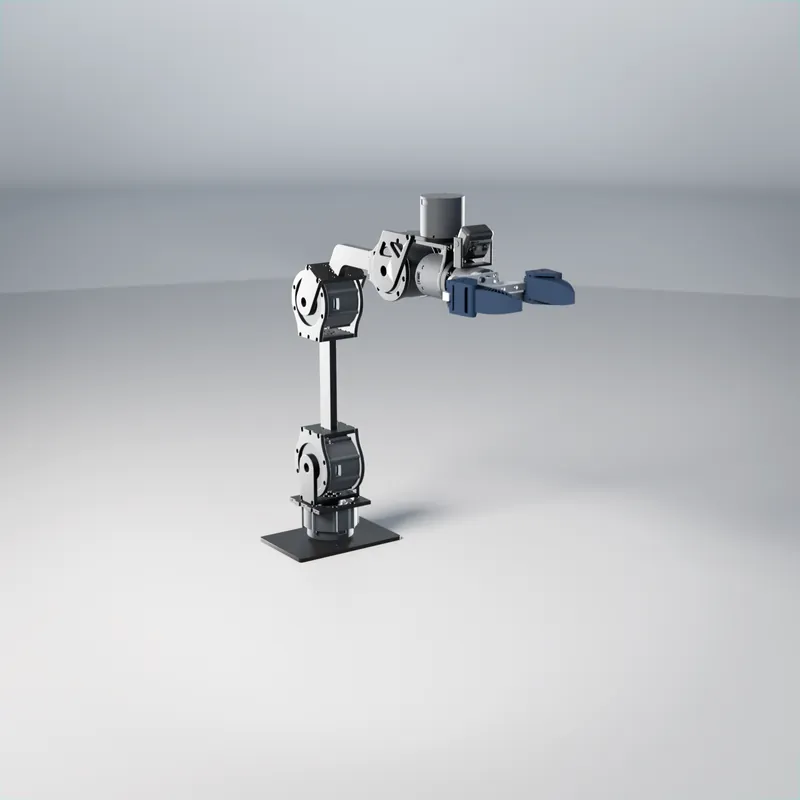 ⇄
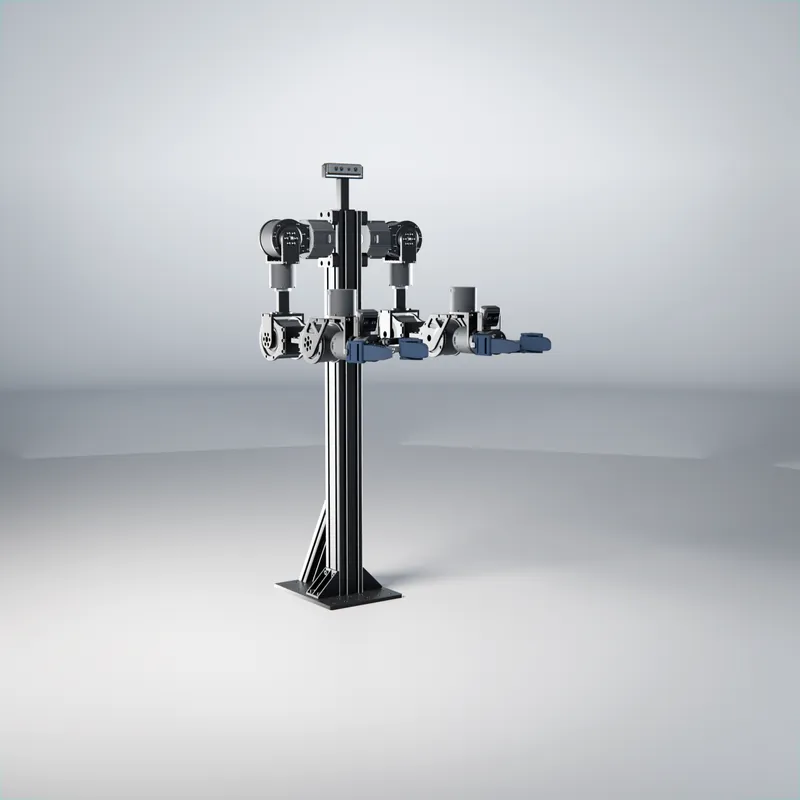
Two separate arms, or both mounted on the stand as an Open Arm.
Shipping, tax and duties are quoted for your address and invoiced before dispatch. Prefer a single robot? See every build · Pre-order terms · Refund policy
Five robots, one actuator set. Leap, climb, map, cook and sort, each from the same modules.
Each build reuses the same actuators, controller and firmware. Buy one on its own, or pair two in a bundle.
Most robot kits become paperweights the day a servo dies. Lucen is designed the other way round.
Every joint is symmetric, every connector is keyed, and every actuator is field-replaceable without a soldering iron.
Every line of firmware and every SDK primitive is on GitHub under MIT. Fork the controller and write your own policy interface.
LeRobot integration, MuJoCo XML, Isaac Sim scenes, and starter notebooks for ACT, SmolVLA and RL locomotion.
Purchase orders, formal quotes and custom configurations, including builds without compute for labs that bring their own. Tell us what you need.
Purchase order or quoteEmail us and we’ll prepare a formal quote for your institution.
Several kits at onceEquip a class or several research teams, quoted together.
Teach locomotion and manipulationOne kit covers both, so a class can move from RL walking to imitation learning.
Repair it yourselvesSpare actuators swap in minutes, so a broken joint doesn’t end the semester.
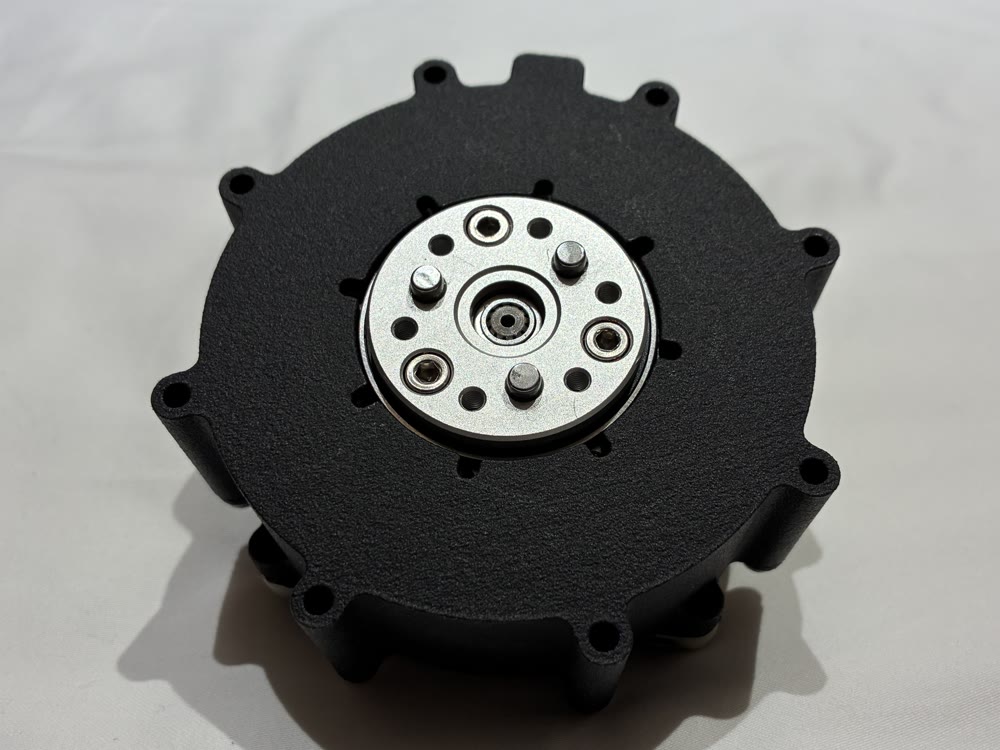
Our own actuator, designed and built in house, for the next generation of every Lucen build.
Orders ship in December 2026. If we can’t make that window, we’ll tell you before it ends with a new date, and you can cancel for a full refund. The details are in our pre-order terms.
Either. A $399 deposit per kit reserves your build at today’s price, and we invoice the balance with shipping, tax and duties before dispatch. Paying in full now works the same way, with only shipping, tax and duties invoiced later.
Yes. Everything you’ve paid, deposit or full price, is fully refundable any time before your robot ships. Email contact@lucenrobotics.com with your order number. See the refund policy.
US orders ship from our US warehouse. Orders to China and international destinations, including Europe, Canada, Japan, Korea and Australia, ship from our warehouse in China, with import duties quoted up front. Not on the list at checkout? Email us.
Every build except the single Arm includes an NVIDIA Jetson Orin Nano Super 8GB. The Arm runs from your own computer. Every arm comes with an RGB wrist camera: one on the Arm, two on the Open Arm and on bundles with two arms. Other builds ship without a camera, and the Quadruped ships without LiDAR or a depth camera. You can add wrist cameras ($99) or a depth camera ($549) at checkout.
Quasi-direct-drive actuators on a CAN bus, with torque control at every joint. Our own in-house actuator is in development for the next generation of Lucen builds.
Email contact@lucenrobotics.com with your institution and the builds you need, and we’ll send a formal quote.
Yes. Firmware, SDK, teleop tools and training notebooks are on GitHub under the MIT license. No account required.
Locomotion and manipulation from the same kit, with open firmware and NVIDIA compute.